TouchBridge: Tactile-Conditioned Human-to-Robot Transfer for Dexterous Manipulation
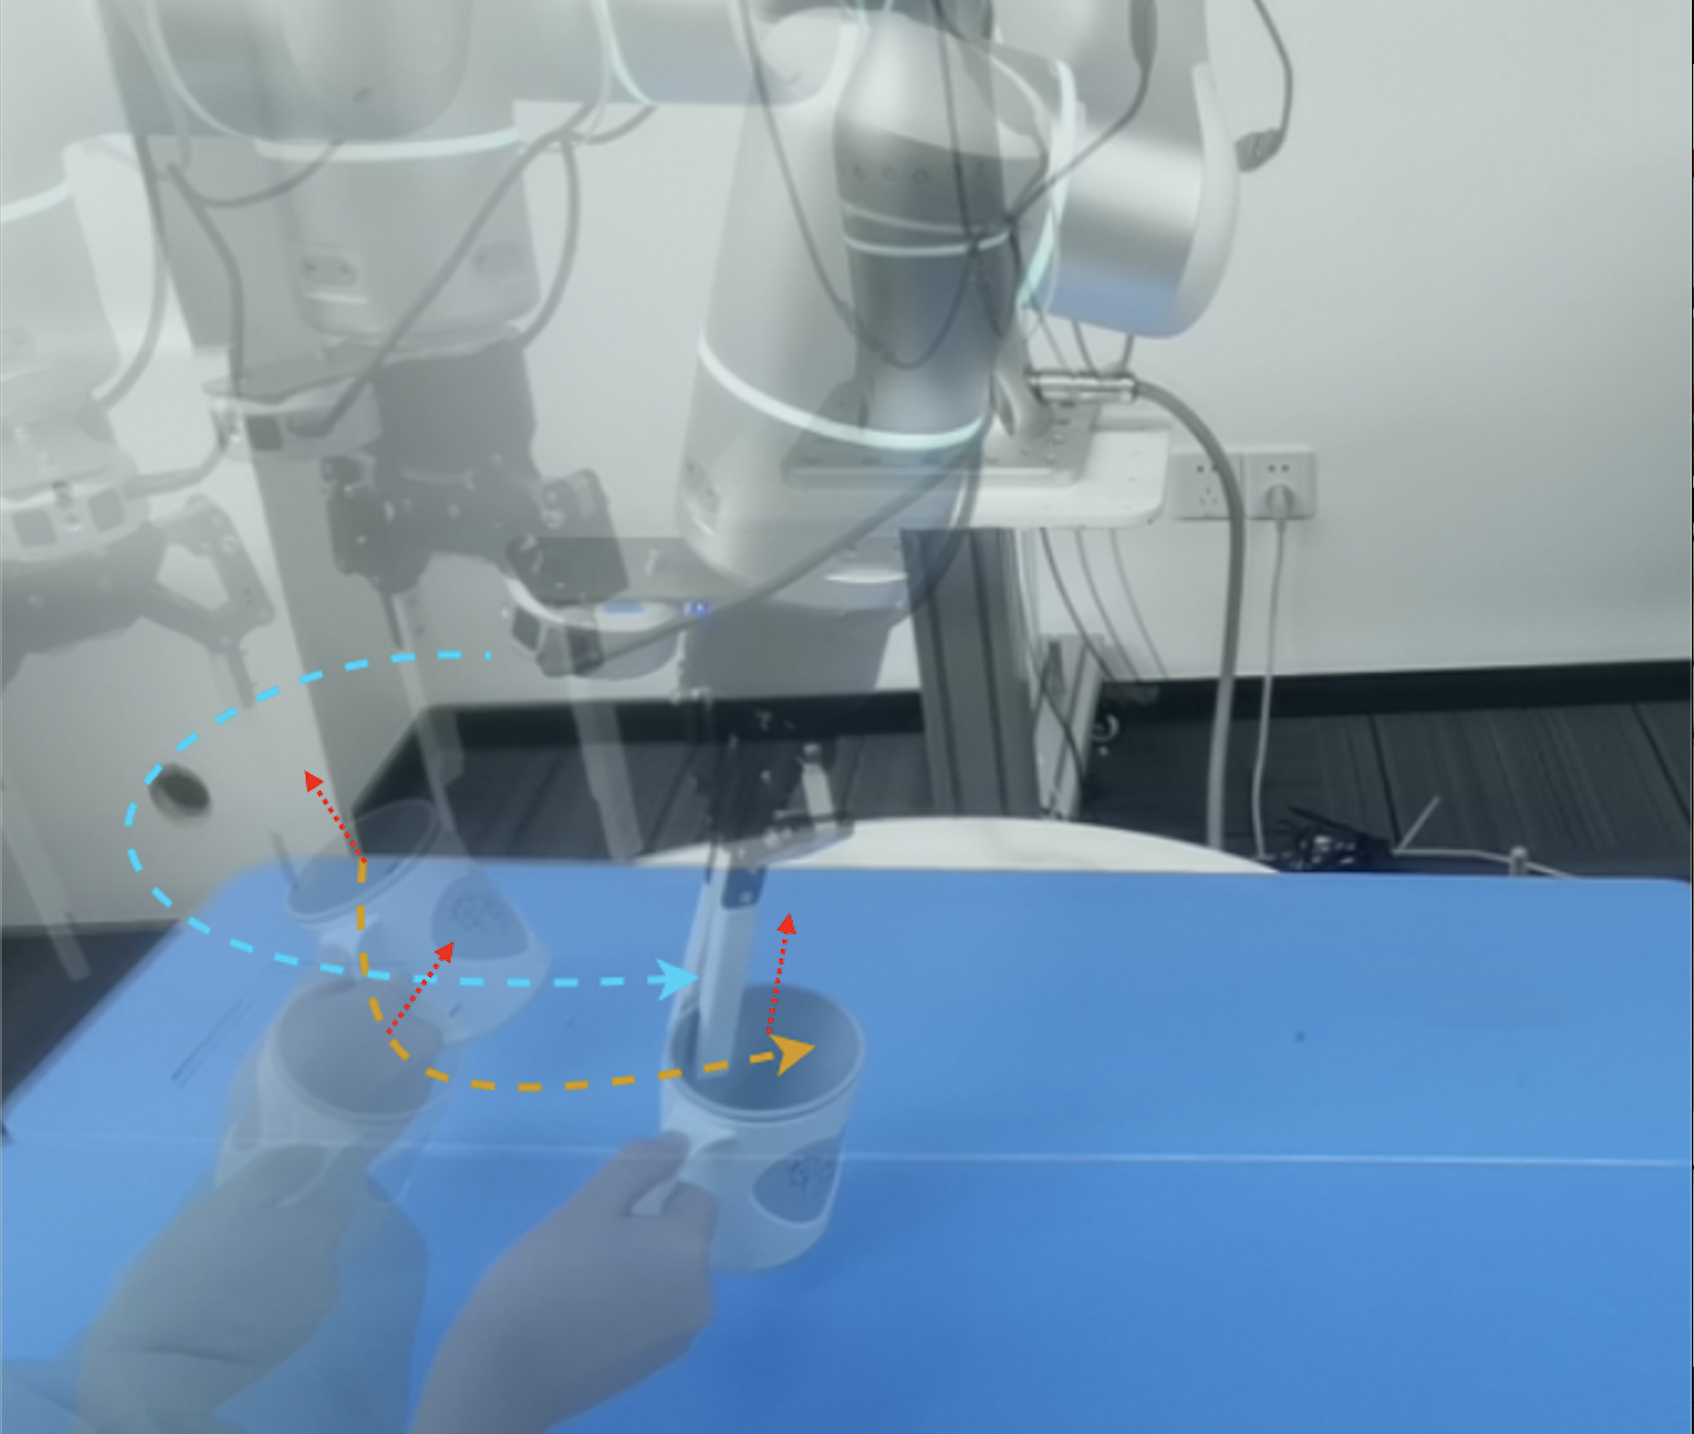
TouchBridge unlocks contact-rich dexterous manipulation from human demonstrations alone. By preserving contact through fingertip touch, it enables autonomous robot policies fine-tuned with zero teleoperated robot data and 7× faster demonstration collection, achieving performance close to policies trained on robot-collected data without object models or simulation.